Description
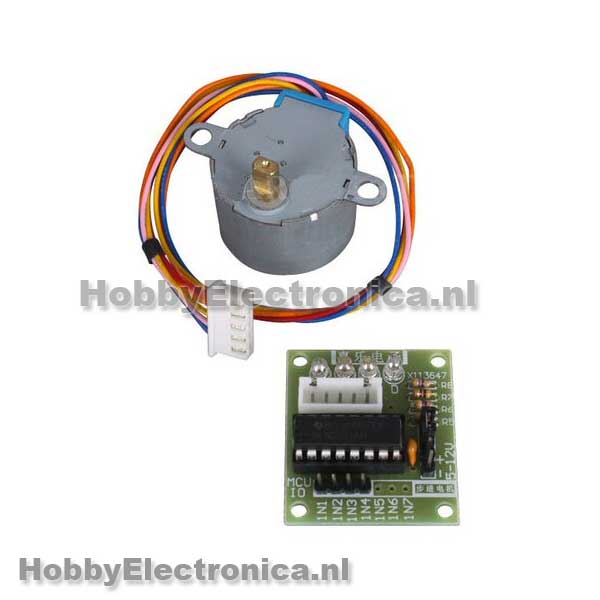
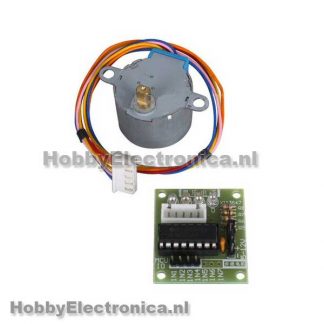
12v stepper motor with ULN2003 driver. 28BYJ-48 high quality stepper motor with ULN2003 driver suitable for microcontrollers.
12v stepper motor with ULN2003 driver specifications:
– Type: 28BYJ-48
– Works on: 12V
– 4-phase
- Diameter: 28mm
– Step angle: 5.625 x 1/64
– Reduction Ratio: 1/64
– 34.3mN.m stall torque
Engine connections:
Connect the motor to the driver board.
connect an Arduino like below:
12V+(red) to +12V
12V to 0V (Ground)
IN1(blue): to Arduino digital input pin 8
IN2(pink): to Arduino digital input pin 9
IN3(yellow): to Arduino digital input pin 10
IN4(orange): to Arduino digital input pin 11
Arduino code example:
// This Arduino example demonstrates bidirectional operation of a
// 28BYJ-48, using a ULN2003 interface board to drive the stepper.
// The 28BYJ-48 motor is a 4-phase, 8-beat motor, geared down by
// a factor of 68. One bipolar winding is on motor pins 1 & 3 and
// the other on motor pins 2 & 4. The step angle is 5.625/64 and the
// operating Frequency is 100pps. Current draw is 92mA.
////////////////////////////////////////////////

//declare variables for the motor pins
int motorPin1 = 8;    // Blue   - 28BYJ48 pin 1
int motorPin2 = 9;    // Pink   - 28BYJ48 pin 2
int motorPin3 = 10;    // Yellow - 28BYJ48 pin 3
int motorPin4 = 11;    // Orange - 28BYJ48 pin 4
                        // Red    - 28BYJ48 pin 5 (VCC)

int motorSpeed = 1200;  //variable to set stepper speed
int count = 0;          // count of steps made
int countsperrev = 512; // number of steps per full revolution
int lookup[8] = {B01000, B01100, B00100, B00110, B00010, B00011, B00001, B01001};

//////////////////////////////////////////////////////////////////////////////
void setup() {
  //declare the motor pins as outputs
  pinMode(motorPin1, OUTPUT);
  pinMode(motorPin2, OUTPUT);
  pinMode(motorPin3, OUTPUT);
  pinMode(motorPin4, OUTPUT);
  Serial.begin(9600);
}

//////////////////////////////////////////////////////////////////////////////
void loop(){
  if(count < countsperrev )
    clockwise();
  else if (count == countsperrev * 2)
    count = 0;
  else
    anticlockwise();
  count++;
}

//////////////////////////////////////////////////////////////////////////////
//set pins to ULN2003 high in sequence from 1 to 4
//delay "motorSpeed" between each pin setting (to determine speed)
void anticlockwise()
{
  for(int i = 0; i < 8; i++)
  {
    setOutput(i);
    delayMicroseconds(motorSpeed);
  }
}

void clockwise()
{
  for(int i = 7; i >= 0; i--)
  {
    setOutput(i);
    delayMicroseconds(motorSpeed);
  }
}

void setOutput(int out)
{
  digitalWrite(motorPin1, bitRead(lookup[out], 0));
  digitalWrite(motorPin2, bitRead(lookup[out], 1));
  digitalWrite(motorPin3, bitRead(lookup[out], 2));
  digitalWrite(motorPin4, bitRead(lookup[out], 3));
}
Only logged in customers who have purchased this product may leave a review.
Shipping within the Netherlands
This product will be delivered via PostNL parcel post.- €6.95 shipping costs for orders under €100.
- Orders above € 100,- will be
park for free sent.
- You can also use parcel convenience.
More information about parcel convenience Ordered before 16:30 PM on workdays, shipped the same day!
Click here for costs outside the Netherlands.
Robert (verified owner) –
Nice stepper motor, not the fastest but very useful for my simple projects.